Zum Hauptinhalt springen
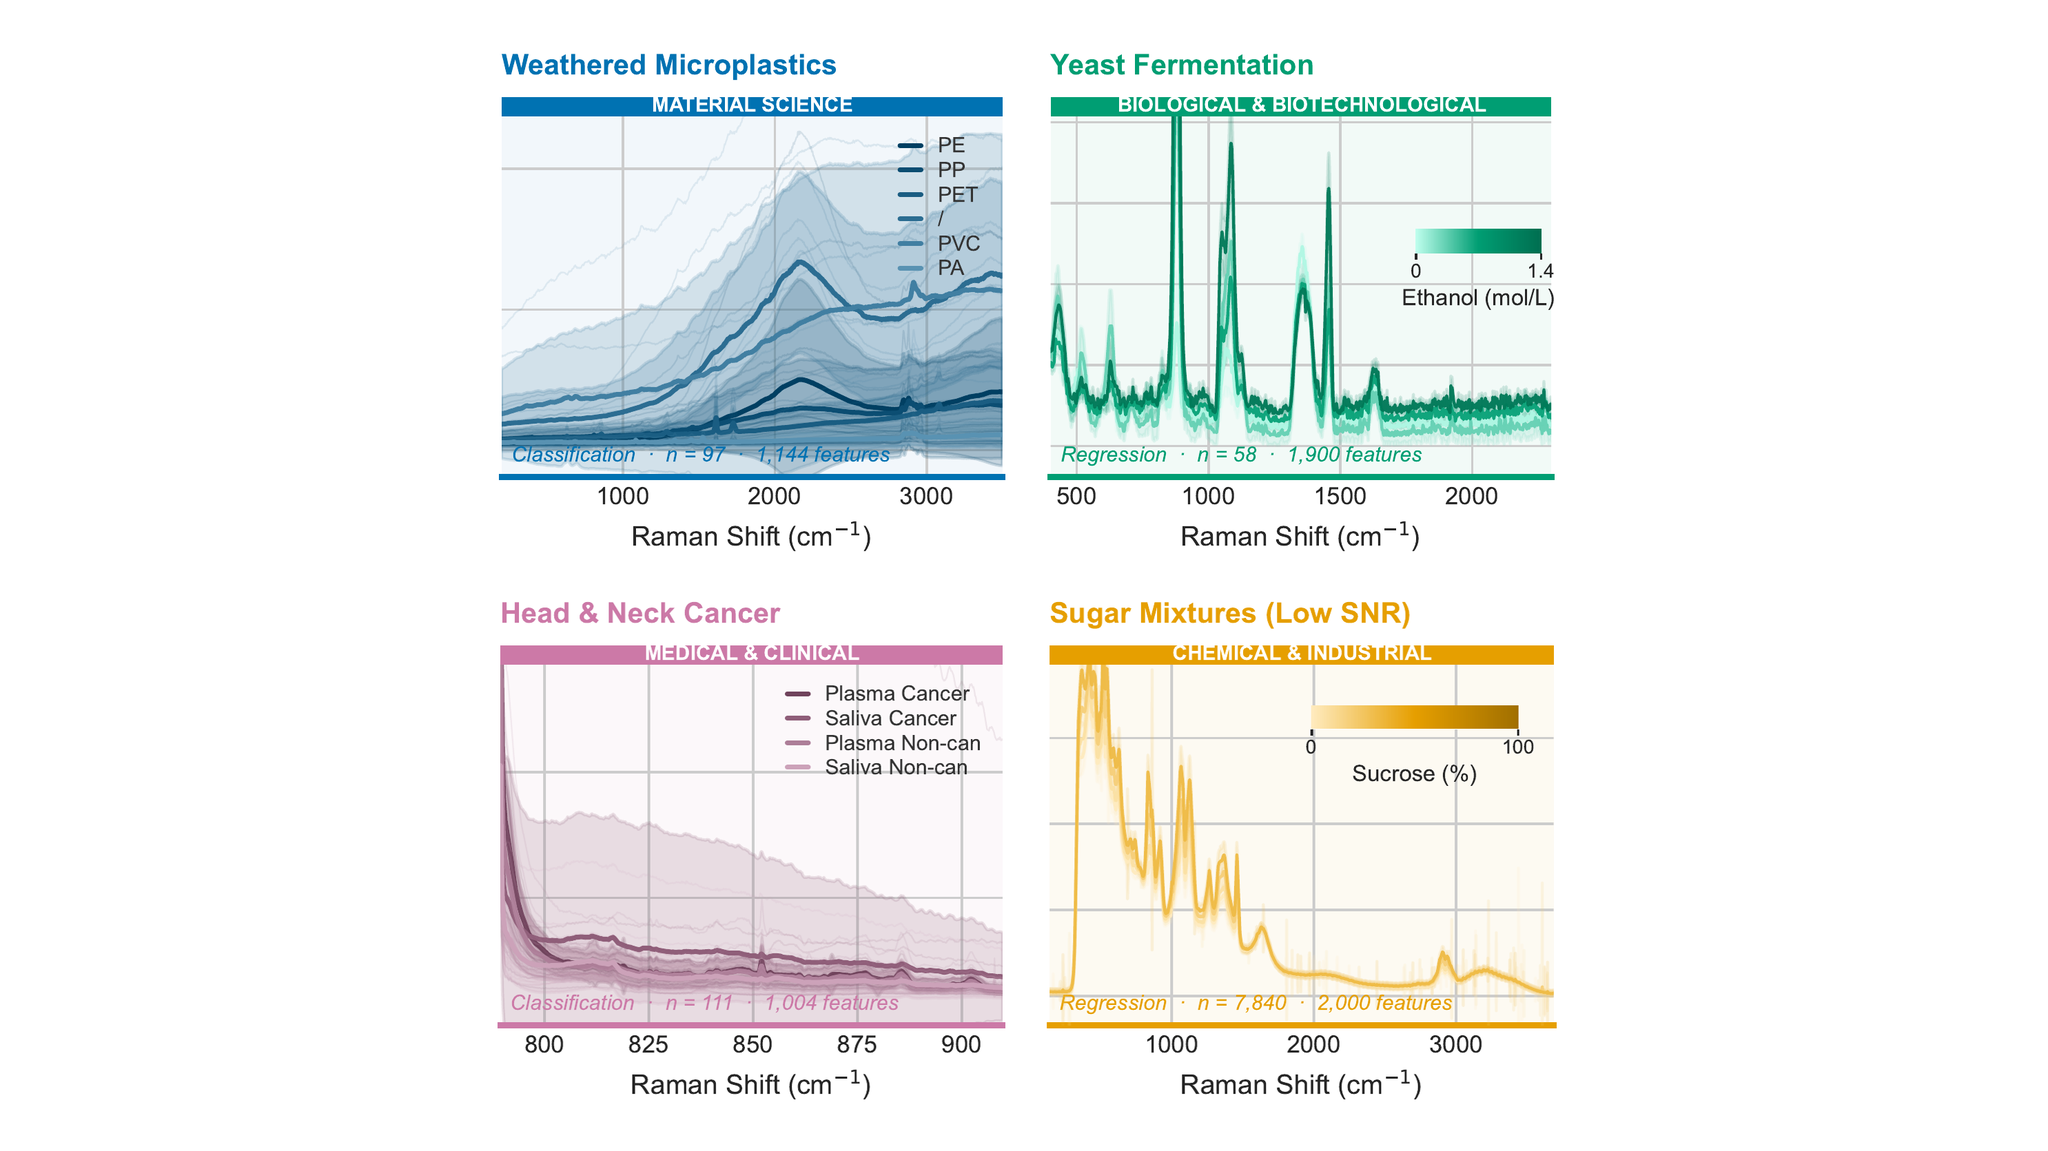
Raman Spectroscopy Had No Benchmark. So We Made One.
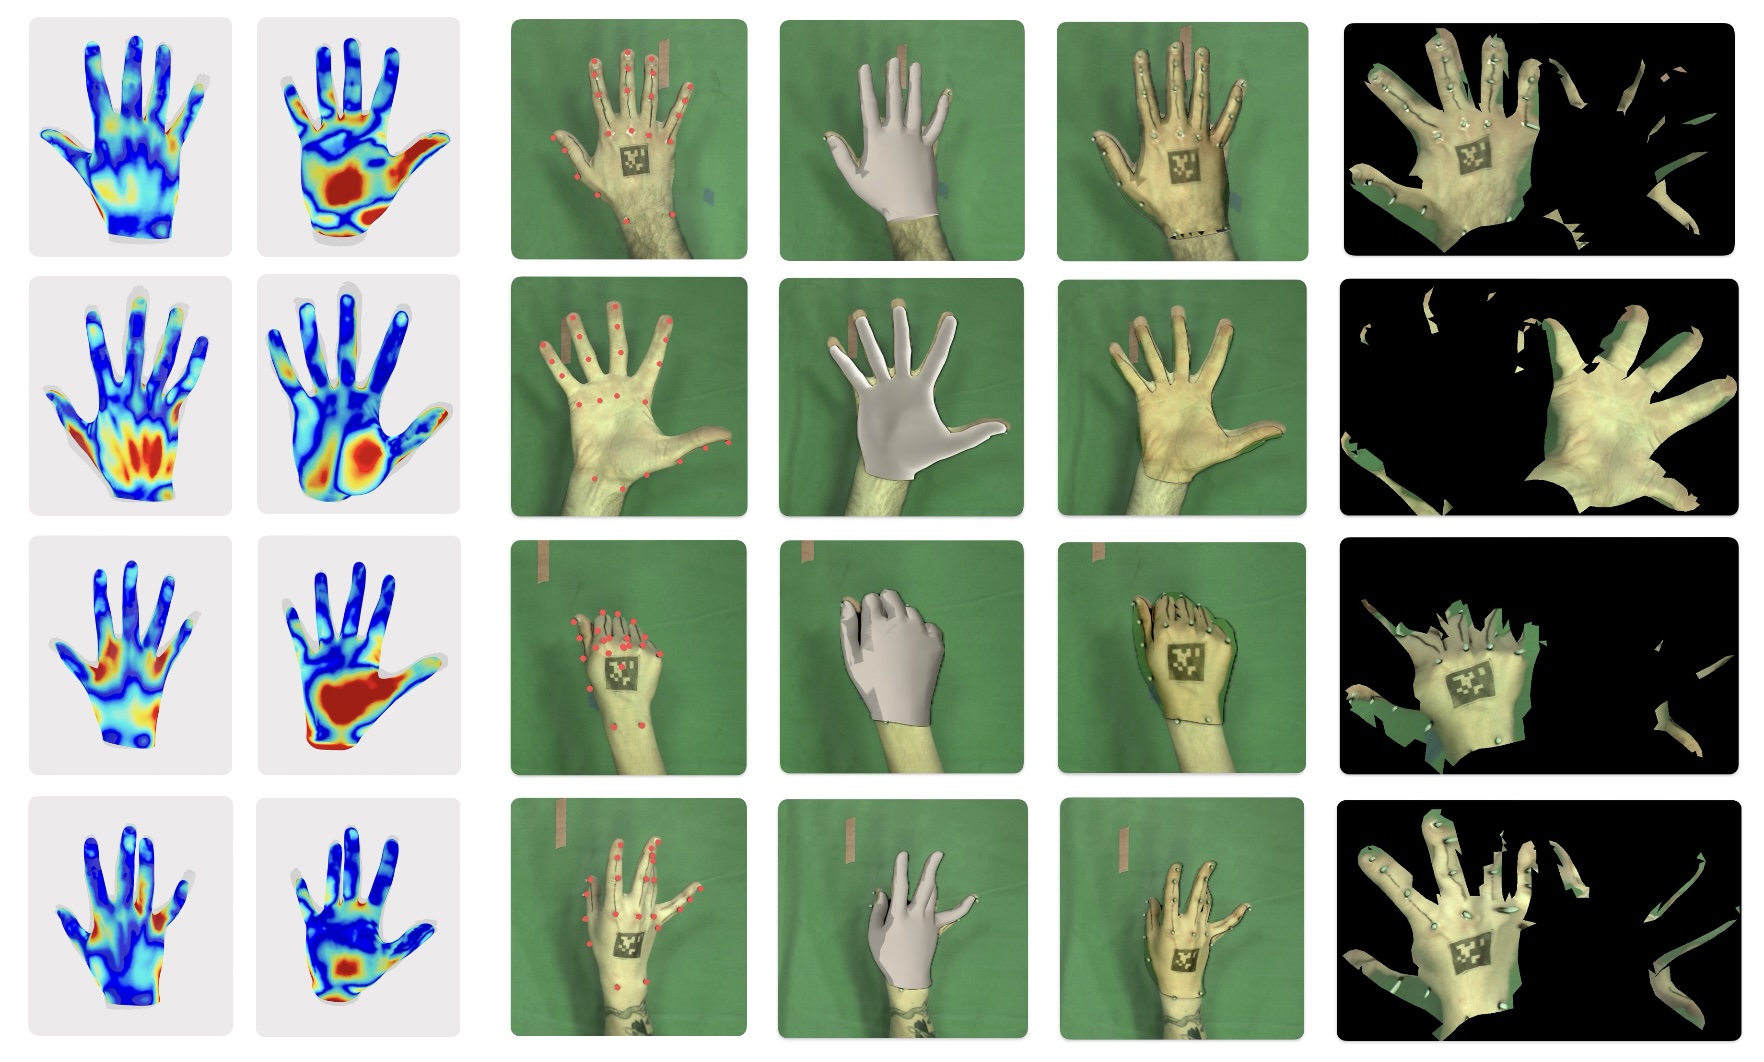
3D Hand Shape Estimation for Video-to-Texture Mapping
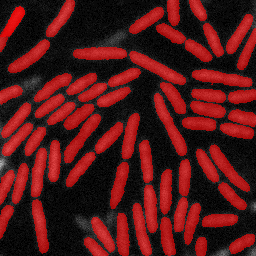
AI-based interactive segmentation approaches for annotating biomedical image data
Embodied AI: Vision-Language-Action Models
Finger Contact Forces from Thermal Signatures
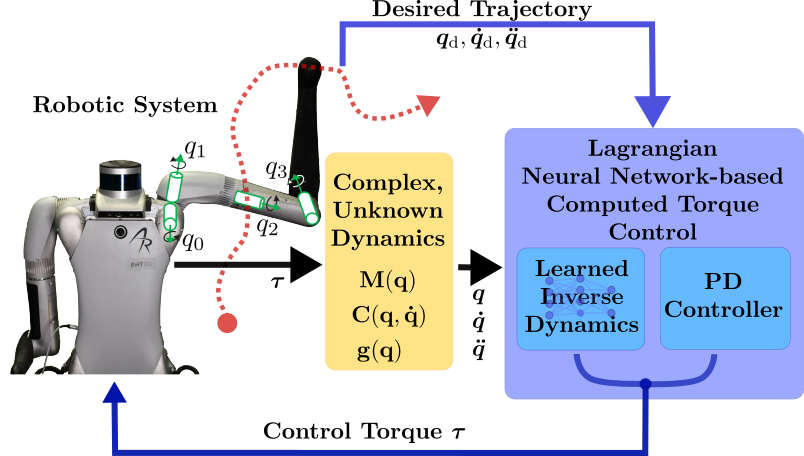
Lagrangian Neural Networks for Computed Torque Control
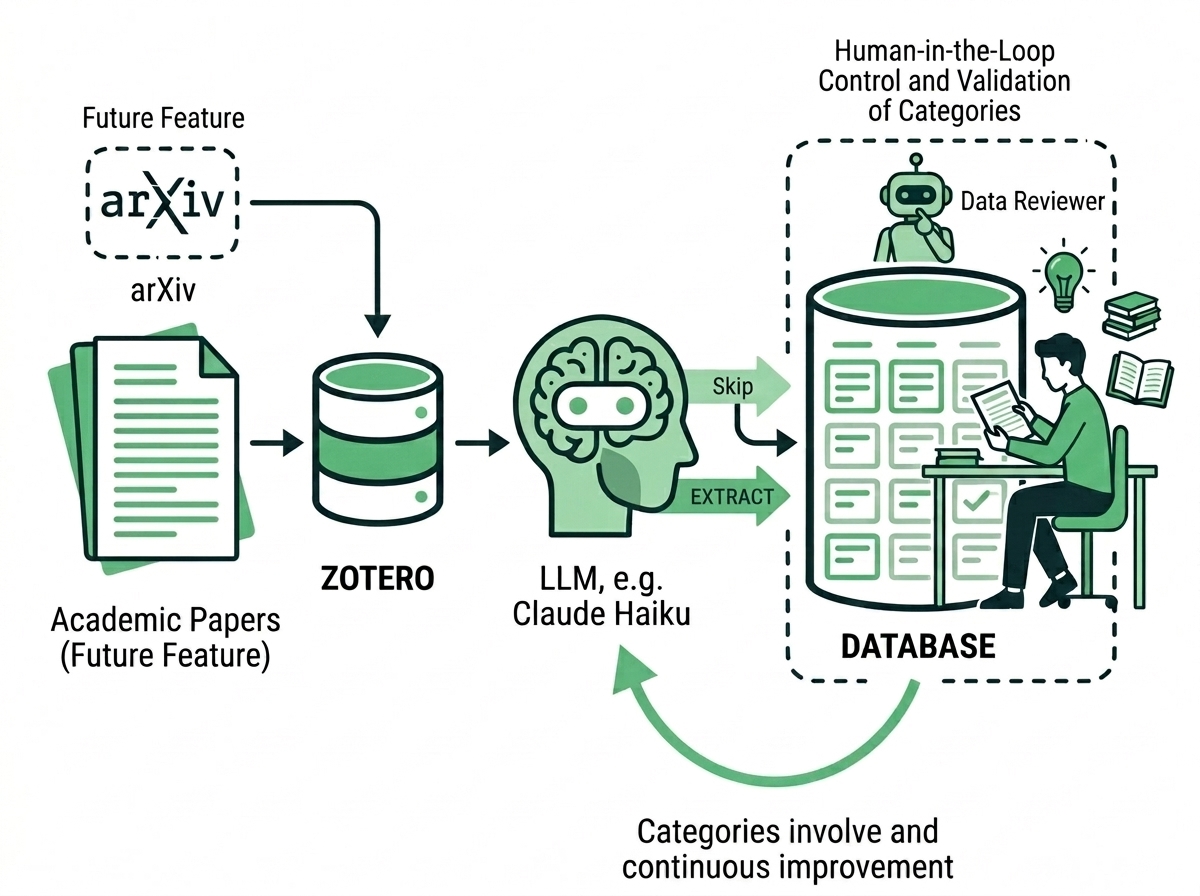
LLMStructBench – Structured JSON data extraction benchmark and evaluation
Morphological Fingerprints of Antibiotic Resistance
Multimodal idiom detection
Predicting Clinical Outcomes
Real-Time Learning Control for Quadruped Robot Velocity Tracking
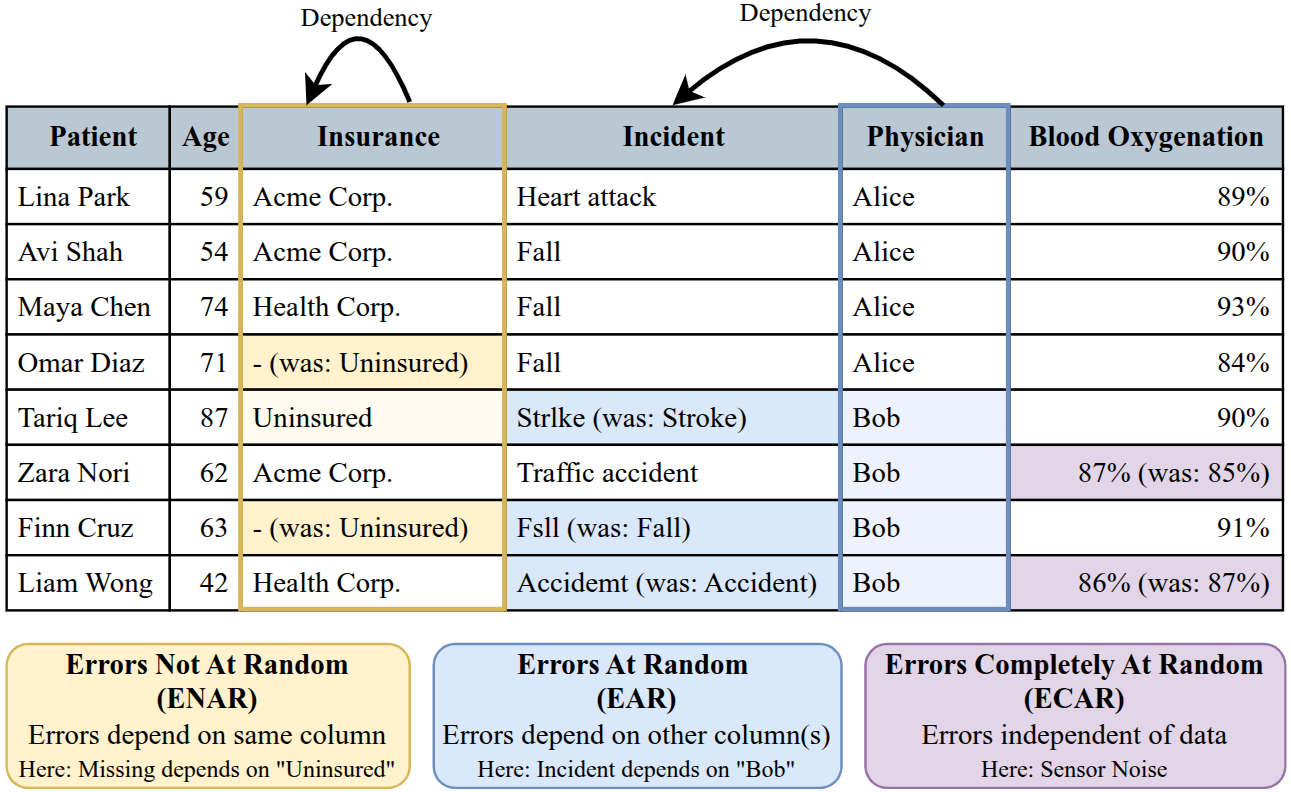
Realistic Errors in Tabular Data
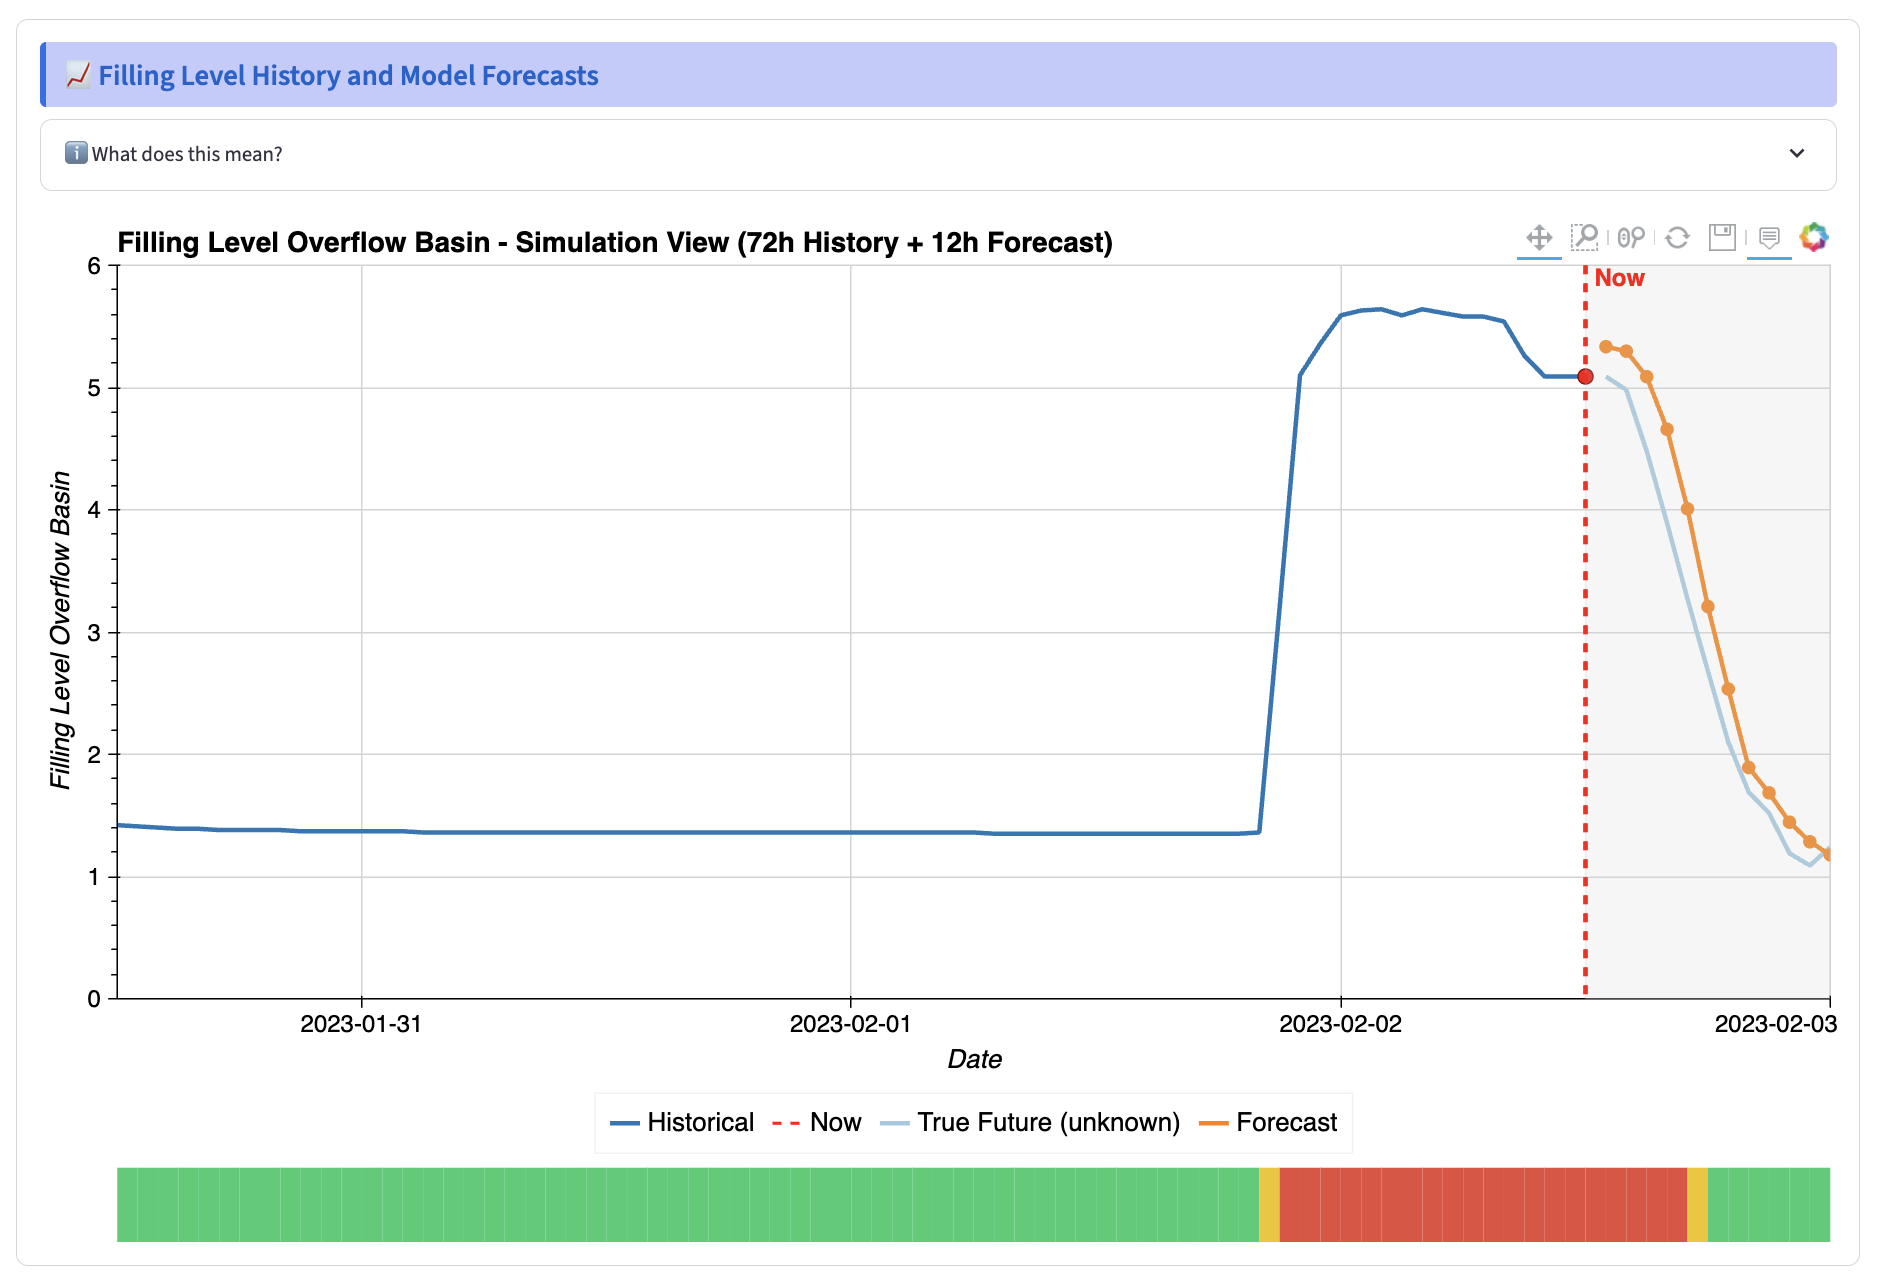
Resilient Time Series Models for Urban Wastewater Management
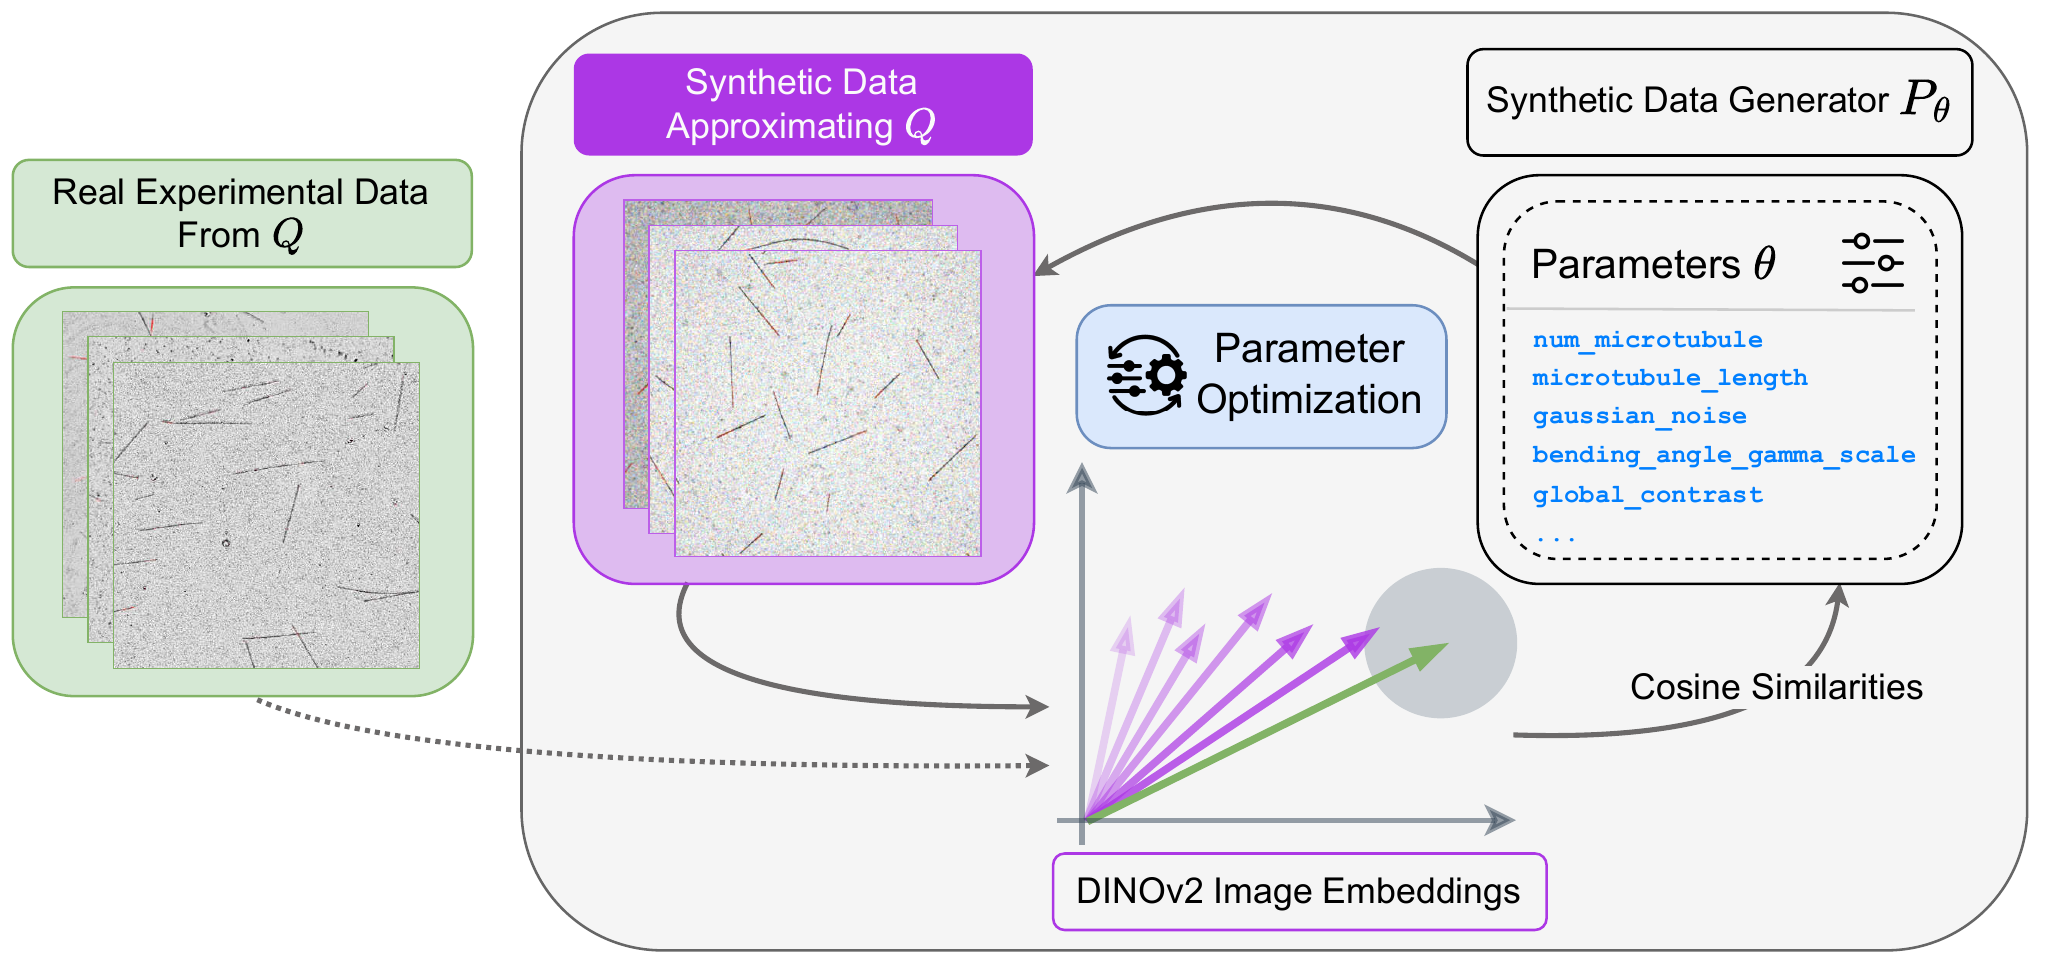
Synthetic Data Enables Human-Grade Microtubule Segmentation with Foundation Models
TabMetaEns: Meta-learning ensemble portfolios for tabular domains with structured statistical fingerprints