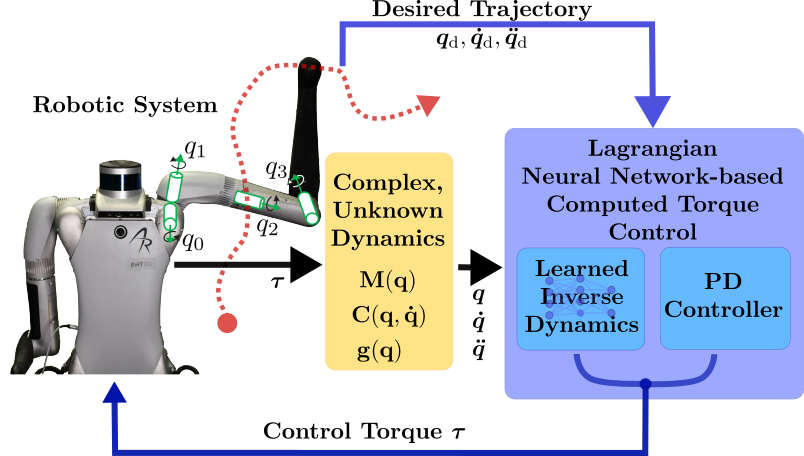
This research presents a physics-informed control framework that integrates Lagrangian Neural Networks (LNNs) into a Computed Torque Control (CTC) architecture for accurate and adaptive robotic trajectory tracking. Instead of relying on precise analytic models, the LNN learns the robot’s inverse dynamics directly from data while enforcing physical consistency through Lagrangian mechanics.
By embedding the learned model inside the feedback-linearization loop (LNN-CTC), the controller shapes the closed-loop error dynamics rather than adding a simple feedforward correction. This results in improved tracking accuracy, robustness to disturbances, and strong generalization with minimal training data, outperforming classical model-based and black-box neural controllers.
An online learning extension continuously updates the LNN during operation, enabling rapid adaptation to dynamic changes such as added payloads. The approach achieves fast gravity compensation, data-efficient learning, and real-time performance without prior model knowledge, making it well suited for robots operating under uncertain and changing conditions.
Lagrangian Neural Networks for Computed Torque Control