 BHT
 LinedIn
 Website

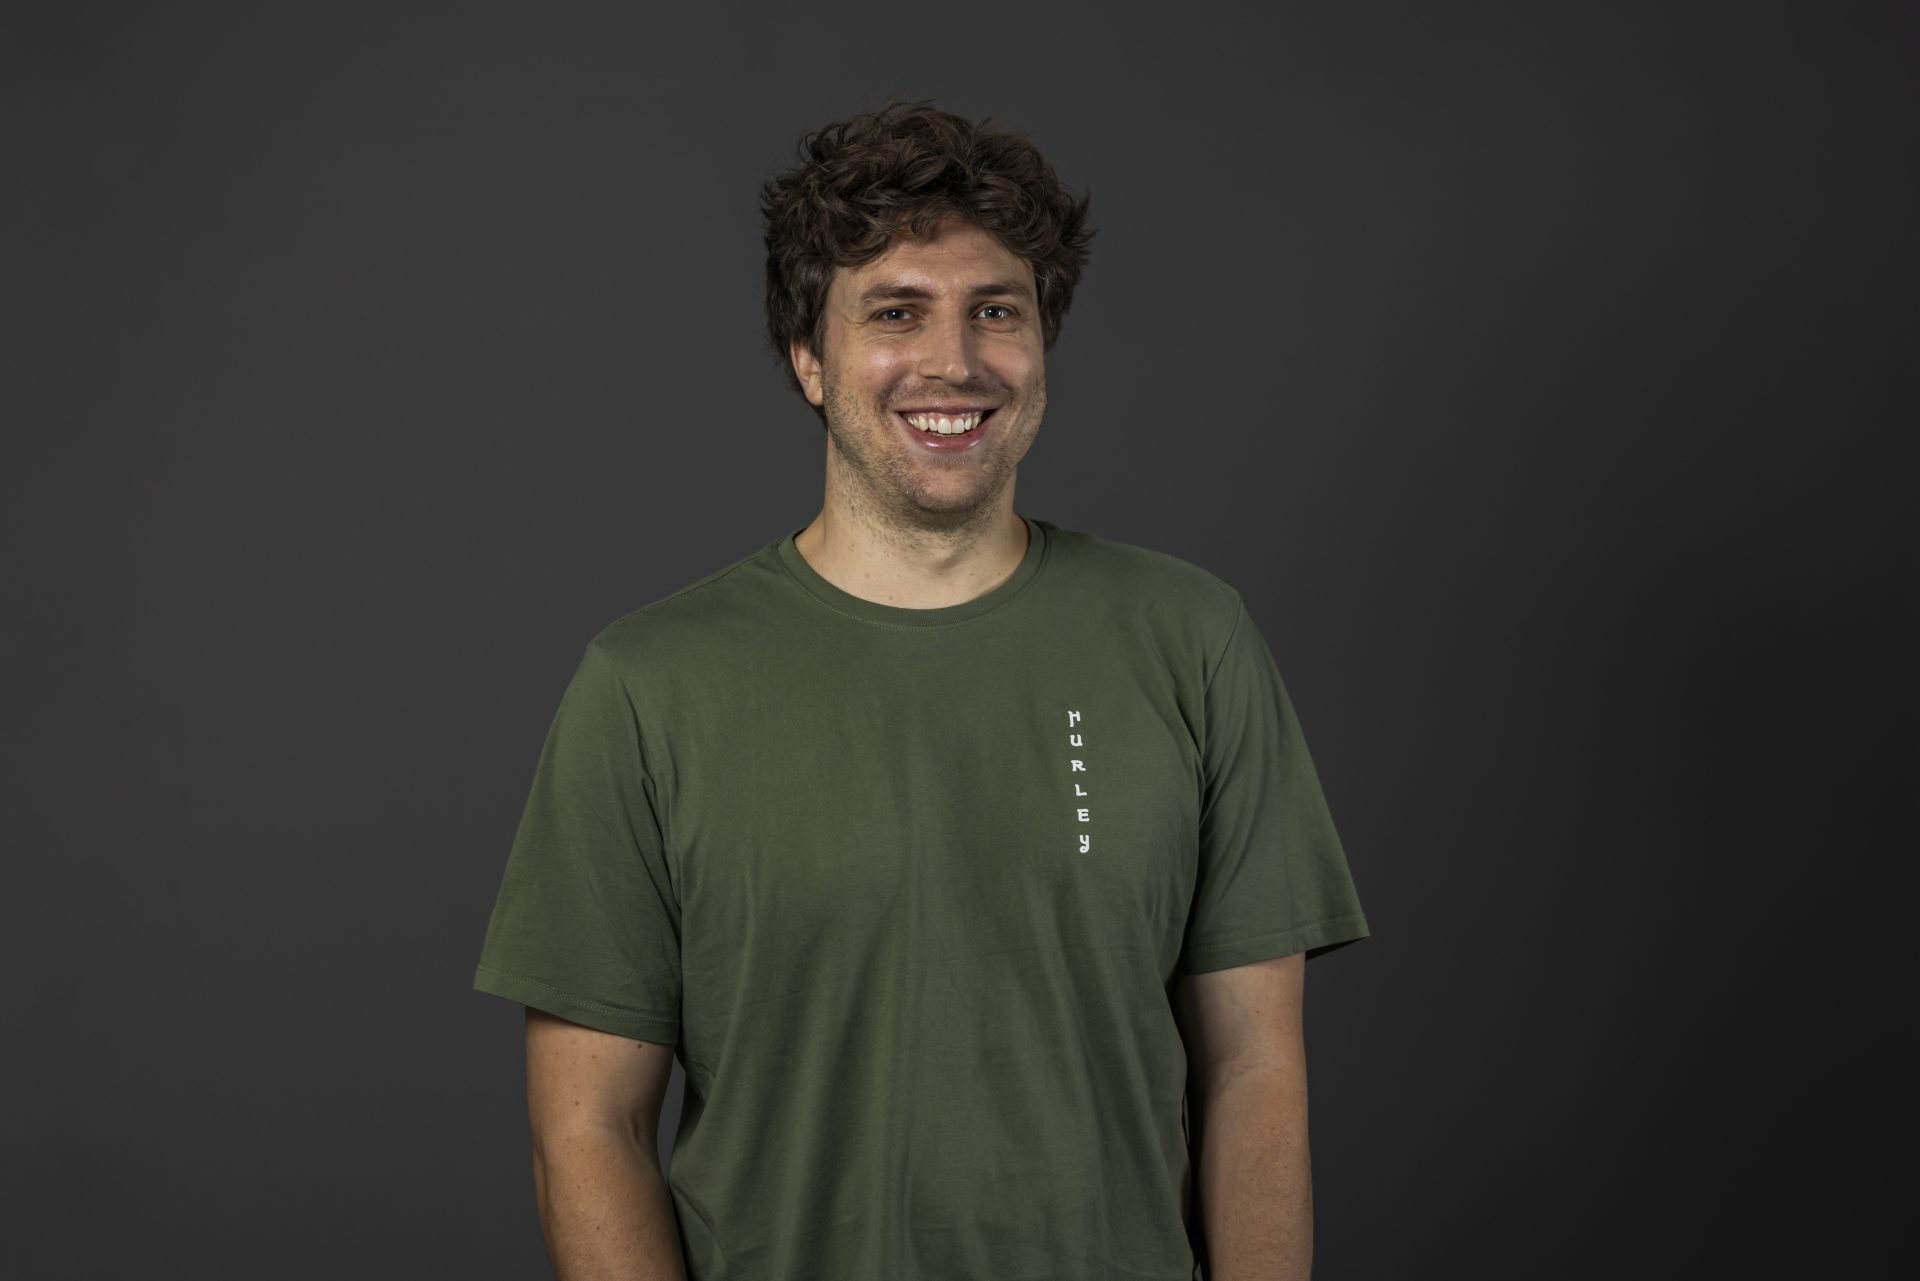
Manuel’s academic background and research mainly cover the areas of physics structured machine learning, data-driven control and sensor fusion for robotic systems. He received his Bachelors in Industrial Engineering with an Electrical Engineering major from Kempten University of Applied Sciences. During his Master’s studies at the BHT he worked on a gesture interface for a quadrocopter and inertial sensor fusion. During this time, he gained substantial experience in the control and machine learning.
His research focuses on making robots move reliably in the messy real world, where models are never perfect and conditions change. He works on data-driven control for robotic systems, aiming to learn from experience while preserving the safety and predictability of proven control principles. The bigger picture is understanding and designing inductive bias in data-driven control: choosing the right built-in assumptions so learned controllers generalize beyond the situations they were trained on. This supports robots that can adapt to new terrains, loads, and contacts, enabling robust mobility and manipulation in everyday environments. Ultimately, the goal is trustworthy autonomy alongside humans. He is currently a PhD student at the Institute of Mechatronic Systems at Leibniz University Hannover, supervised by Prof. Dr.-Ing. Thomas Seel and Prof. Dr.-Ing. Ivo Boblan.
Publications
- Achieving Velocity Tracking Despite Model Uncertainty for a Quadruped Robot with a PD-ILC Controller
- Learning of a Rapid Prototyping Gait Library for a Quadruped Robot Using PD-ILC and Gaussian Processes
- Learning by doing: Online Learning to Compensate Gravity with a Computed Torque Controller using Lagrangian Neural Networks
- Lagrangian Neural Network-Based Control: Improving Robotic Trajectory Tracking via Linearized Feedback