 BHT
 LinkedIn Profil
 hannes.hoeppner@bht-berlin.de
Research Profile
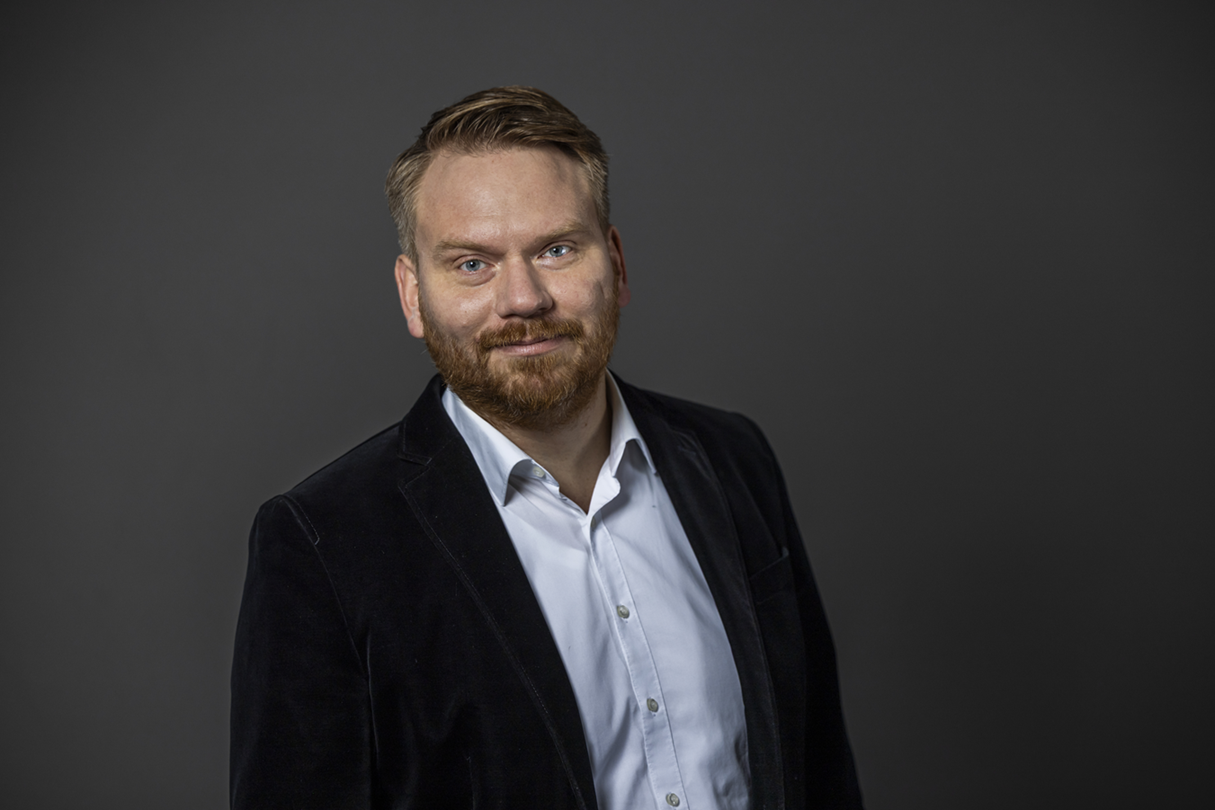
Hannes Höppner is Professor of Humanoid Robotics at the Berlin University of Applied Sciences and Technology (BHT). He has worked at BHT since October 2019 and heads the Soft Interactive Robotics Laboratory (SIRo Lab). His research focuses on physically interactive humanoid robotics. Key topics include compliant and variable-stiffness mechanisms, dexterous manipulation, teleinteraction, and robot learning from human demonstrations. A central theme is the exploitation of mechanical intelligence. This approach aims to improve robustness, safety, and controllability in physical interaction.
Current Research at the SIRo Lab
Current research at the SIRo Lab covers soft robotic hands, variable-stiffness actuation, and visuo-haptic teleoperation. In particular, recent work investigates 3D-printed nonlinear torsional springs, Bowden-based actuation, and mechanically adaptive fingertips. These approaches support robust grasping and manipulation in complex environments.
In addition, Höppner leads the DFG-funded project tele.interaction. The project investigates intuitive visuo-haptic teleoperation of compliant robotic systems. At the same time, the SIRo-AEMP project transfers the lab’s soft-hand research toward real-world manipulation of surgical instruments.
Research within APPL-FM
Within the DFG-funded research initiative APPL-FM, Höppner contributes to the research scenario Robotics and Behavioral Learning. His group investigates how complex robot manipulation skills can be learned from human demonstrations. These skills are represented as reusable Motion Primitives. Subsequently, they can be adapted to new situations and combined into structured skill libraries.
Moreover, a current focus is the integration of these learned skills with Foundation Models and Large Language Models. Here, the language model serves as a high-level planning layer. It decomposes human instructions into individual actions and selects appropriate skills. Meanwhile, conventional robot control and soft-robotic mechanisms execute and adapt the corresponding interactive motions.
Academic Background
Höppner received his Dr.-Ing. from the Technical University of Munich in 2016. His doctoral research addressed human intrinsic stiffness modulation and its transfer to variable-stiffness robotic systems.
From 2009 to 2018, he worked as a research scientist at the German Aerospace Center (DLR). His research included variable-stiffness humanoid systems, hand biomechanics, compliant robotic hands, and safe physical human-robot interaction. During this period, he also contributed to the EU project SoMa.
From 2018 to 2019, he led technology and measurement-system development at the Institute for Applied Training Science (IAT) in Leipzig. Furthermore, his work has received several awards, including the KUKA Innovation Award in 2017 and the DLR Idea Award in 2018.
Publications
- Variable Stiffness Actuation via 3D-Printed Nonlinear Torsional Springs
- VSB – Variable Stiffness Based on Bowden Cables: A Simple Mechanism for Soft Robotic Hands
- Programming Passive Fingertip Deformation for Improved Grasping and Manipulation
- From Heat to Force: Retrospective Estimation of Finger Contact Forces from Thermal Signatures